6-Axis Depalletizing Robot

6-Axis Depalletizing Robot

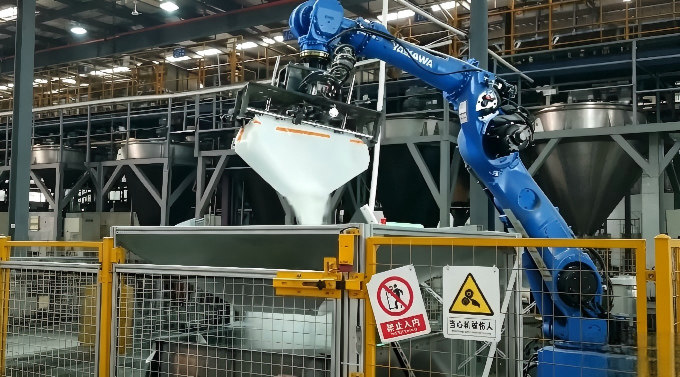
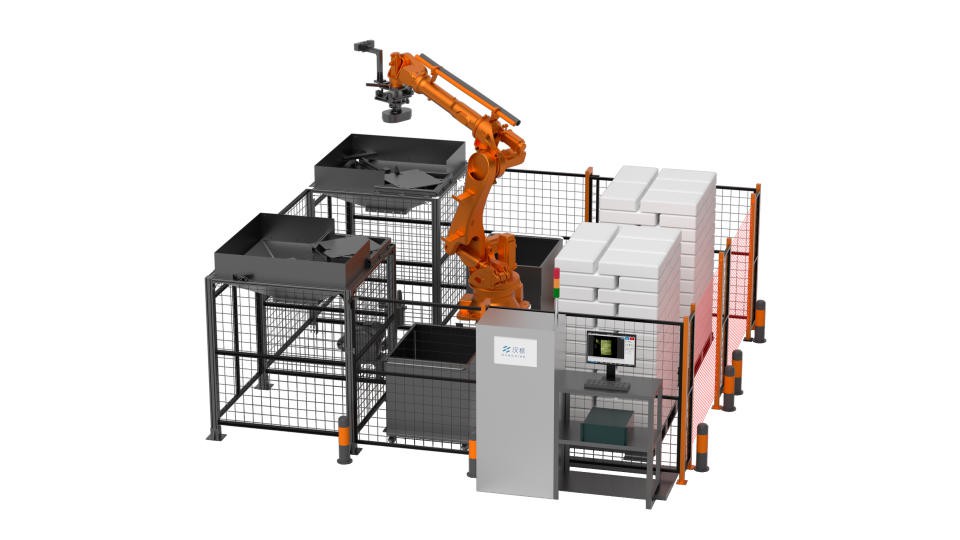
Utilizing the more rigid mechanical structure and faster motion cycles of a six-axis column-mounted robot compared to a four-axis design, and combined with specialized grippers (such as vacuum suction cups or mechanical clamps), high-speed and high-stability automatic grasping and precise feeding of bagged materials such as plastic pellets, powders, chemical raw materials, and food can be achieved. The system can transfer materials from pallets to designated feed inlets in shorter cycles, ensuring smooth operation while significantly improving the overall efficiency of fully automatic pallet unloading operations.


Products Parameter


Feeding Efficiency​

~3.5-4 tons/hour


Smart Connectivity

Multi-protocol workshop network access

Auto-log & upload to MES

Ensures high-cycle production
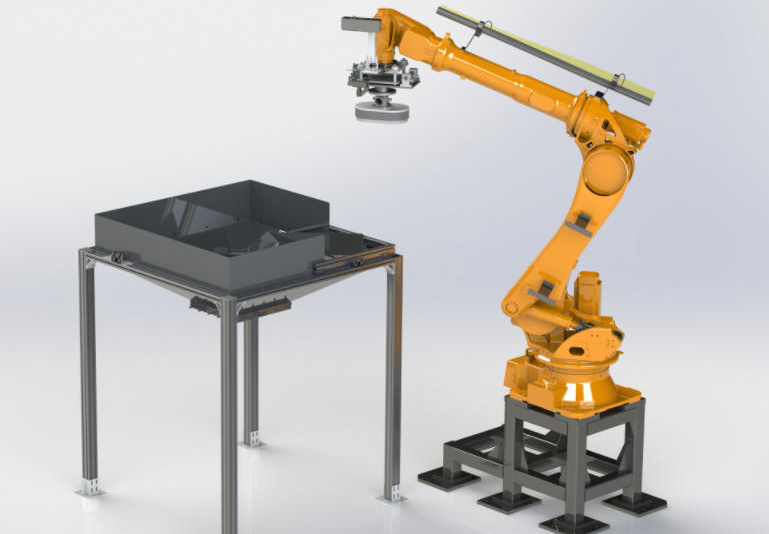
product-769-534
3111

Optional models:

Estun, Yaskawa, ABB, KUKA.

Bridge the Final Mile

Warehouse to line seamlessly

Data & logistics dual closed-loop

Locking smart factory key nodes


Technical parameters


Material

Specification

Material PP/PE/PVC/Sugar/Flour/Rice, etc.
Material Type Granule/Powder
Bag Material PE/Woven Bag/Kraft Paper Bag
Pack Weight 25kg/50kg
Pack Size (mm) 660/440/150
Pallet Size (mm) 1100/1300
Total Stack Height 2.1m

Function

Speed 160 Bags/h


Robot


6-Axis 6-Axis
Residue 6g/Bag Maximum Payload 100kg
Gripper Type Pin Gripper/suction cup Maximum Reach Radius 3200mm
Loading/Unloading Stations Single Station/Multi-Station Repeat Positioning Accuracy ±0.5mm
Dust Removal Requirement According to Customer Requirements Weight 1120kg
Empty Bag Handling Waste Bag Bin

Optional models

ESTUN, YASKAWA, ABB, KUKA
Installation Scenario Space Height At least 4m ★ Remarks Customized solutions are available.
Space Size (L×W×H) 3.6m×6.5m×6.5m (360° Operation)
Floor Material Concrete/Steel Platform


Product operation video


Products Certifications
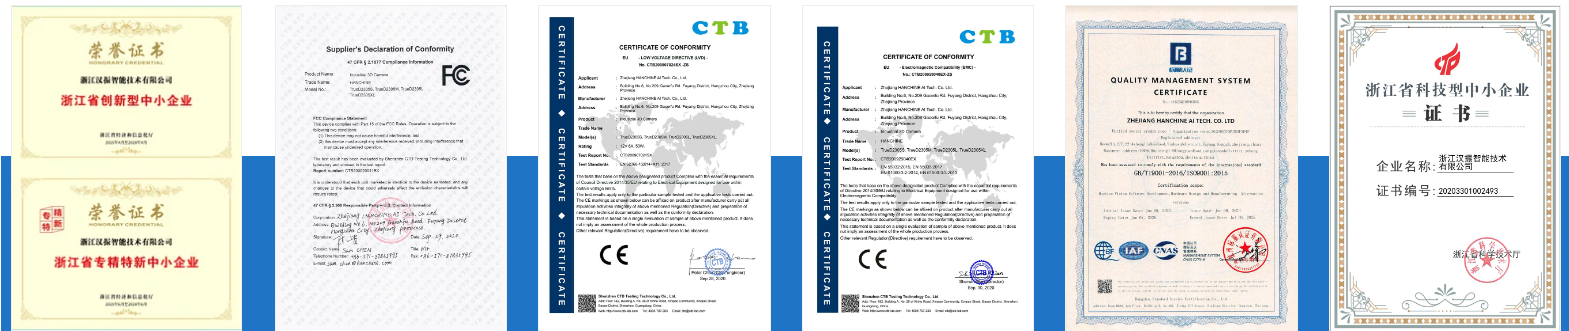
 

Products Certifications


Frequently Asked Questions
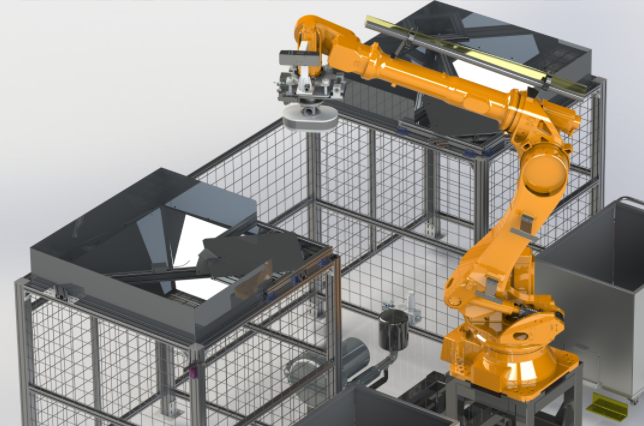
 

product-644-426
 

Q1:When failure or an error occurs, can the cause of the problem be quickly located?

 A1:Yes. The first is a hardware issue with the gripper, which may cause dropped items during grasping; in this case, you only need to check the hardware. The second is a deviation between the grasping point and the detection point. We can re-calibrate our points by using the relative position offset between the points given by the software and the actual grasping points to achieve a correction function.

Q2:How does the system handle common lighting changes in a warehouse environment (such as morning and evening sunlight, light switching)?

 A2:Simply avoid direct sunlight.

Q3:Can robot end effectors (suction cups, grippers) be customized according to the characteristics of our materials (such as material and weight)?

A3:Yes, we provide customized services. Because different packaging materials have different lengths, widths, and heights, our corresponding materials, needle lengths, and sponges will be adjusted accordingly.

Q4:Is the control system easily integrated with our existing Warehouse Management System (WMS) or logistics line control system?

A4:Yes, different manufacturers have different communication protocols. We can customize our corresponding parameters for reading based on the communication protocol.


Hot Tags: 6-axis depalletizing robot, China 6-axis depalletizing robot manufacturers, suppliers, Automated Depalletizing, Automatic debagging robot, Automatic unpacking machine, Bag breaking station , de-palletizers, Sack opener

Send Inquiry