Mobile Mobi Depalletizing Robot

Mobile Mobi Depalletizing Robot

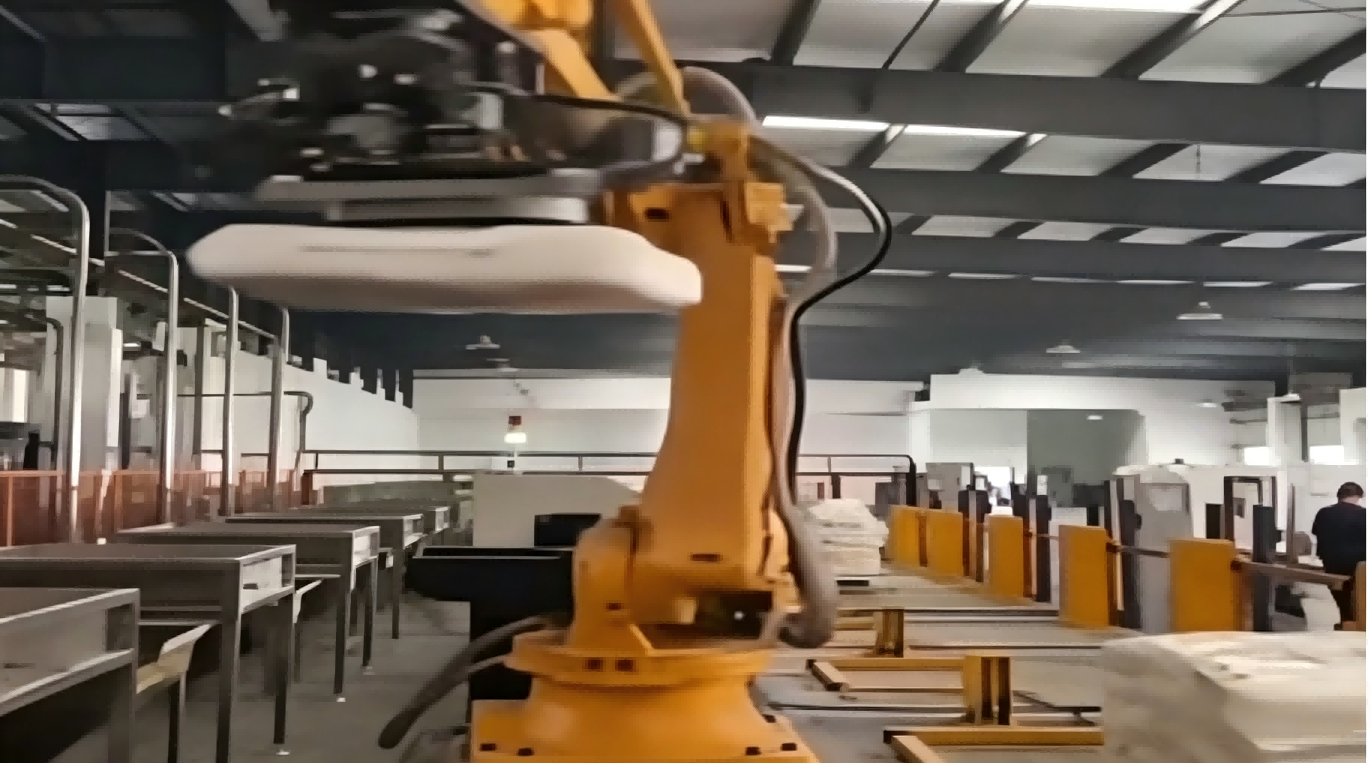
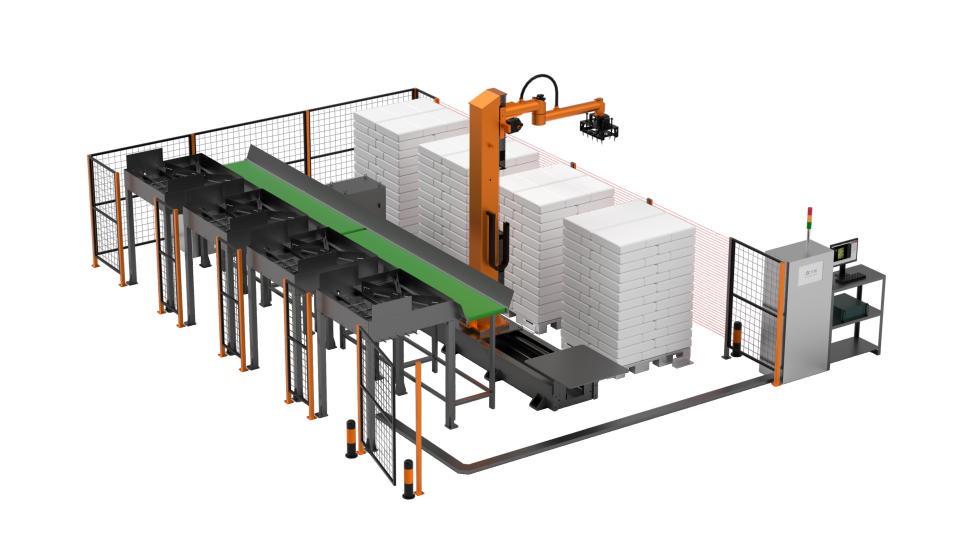
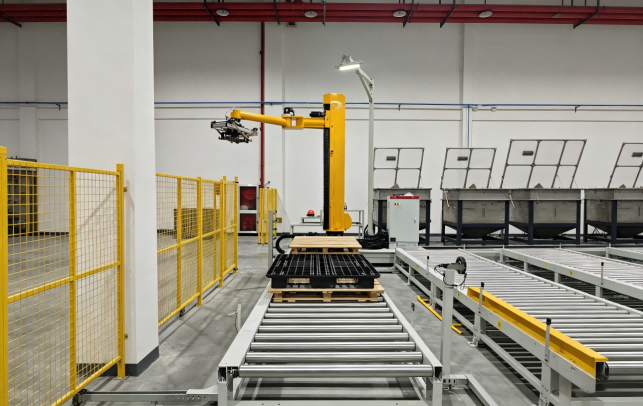
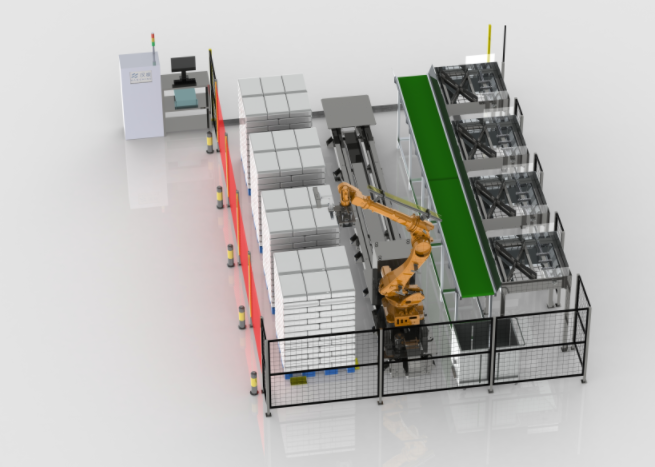
A mobile depalletizing robot is an intelligent device that integrates an autonomously navigating mobile chassis​ and an industrial-grade robotic arm. It utilizes an AGV/AMR chassis​ for flexible transportation across workstations and areas, and employs an integrated vision recognition system​ along with an end-effector​ (such as vacuum suction cups or mechanical grippers) to automatically perform high-precision positioning, grasping, transporting, and depalletizing​ of pallets, containers, or bagged materials without human intervention. It serves as a core solution for achieving integrated "automatic material flow + precise feeding" in flexible manufacturing and smart warehousing scenarios.


Products Parameter


One‑Machine Multi‑Port Feeding​

Delivers by formula, boosts changeover accuracy.

High Real-Time & Stable​

Simple, flexible system configuration.
2
1

Modular & Permission-Controlled​

Modular program structure with user access levels.

Flexible Changeover​

Tackles multi-variety, small-batch challenges, boosts line flexibility.


Technical parameters


Material

Specification

Material PP/PE/PVC/Sugar/Flour/Rice, etc.
Material Type Granule/Powder
Bag Material PE/Woven Bag/Kraft Paper Bag
Pack Weight 25kg/50kg
Pack Size (mm) 660/440/150
Pallet Size (mm) 1100/1300
Total Stack Height 2.1m

Function

Residue Requirement 6g/Bag

Robot

Column 4-axis / 6-axis
Loading/Unloading Stations Multi-Station
Customer Receiving Mechanism Mixer/Reactor/Feeding System
Dust Removal Requirement According to Customer Requirements ★ Remarks Customized solutions are available.
Empty Bag Handling Waste Bag Bin


Product operation video


Frequently Asked Questions
 

product-655-467
 

Q1:Does this vision system require frequent manual calibration?

 A1:No. Normally, after the robot installation is completed, we perform a camera calibration during the debugging phase. After calibration, the relative position of the camera image and the robot's relative position are bound together. As long as the machine is not relocated or the robot does not lose power (e.g., origin loss), the points remain fixed and will not change.

Q2:Can robot end effectors (suction cups, grippers) be customized according to the characteristics of our materials (such as material and weight)?

 A2:Yes, we provide customized services. Because different packaging materials have different lengths, widths, and heights, our corresponding materials, needle lengths, and sponges will be adjusted accordingly.

Q3:When failure or an error occurs, can the cause of the problem be quickly located?

A3:Yes. The first is a hardware issue with the gripper, which may cause dropped items during grasping; in this case, you only need to check the hardware. The second is a deviation between the grasping point and the detection point. We can re-calibrate our points by using the relative position offset between the points given by the software and the actual grasping points to achieve a correction function.

Q4:Do you provide on-site technical support during equipment installation and commissioning? Will you provide systematic training for our operators and maintenance personnel? What does the training include?

A4:Yes, we will provide an operating manual for the equipment, including maintenance precautions, and will provide written guidance as well as on-site guidance.


Hot Tags: mobile mobi depalletizing robot, China mobile mobi depalletizing robot manufacturers, suppliers, Automatic unpacking machine, case depalletizer, industrial robot, Plastic pellet bag slitting machine , Replace manual bag breaking, Robotic unpacking system

Send Inquiry